ISO 10816-3: Vibration Limits for Industrial Machines
A practical summary of ISO 10816-3:2009 for on-site vibration checks on industrial machine sets above 15 kW that run between 120 and 15,000 r/min: evaluation zones A to D in RMS velocity and displacement, two machine groups, two support classes, the change criterion and guidance on ALARM and TRIP settings.
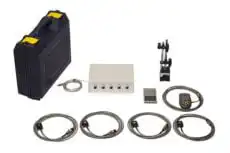
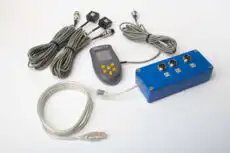
A portable instrument such as the Balanset-1A measures broadband RMS vibration velocity on bearing housings; its default band of 10 Hz to about 1 kHz matches the band used here for most machines. You compare the reading with the tables below yourself, because the Balanset software does not assign ISO 10816-3 zones automatically.
Quick Reference: Vibration Severity Limits
Zone boundaries of ISO 10816-3:2009, Annex A: Table A.1 for Group 1 and Table A.2 for Group 2. All values are broadband RMS, taken in the radial direction on bearing housings or pedestals while the machine runs steadily.
Frequency band: 10–1000 Hz, or 2–1000 Hz for machines running below 600 r/min. Determine the machine group and the support class first, then read off the zone.
Evaluation Criteria — RMS Velocity (mm/s)
ISO 10816-3 zone boundary values for industrial machines
| Machine Group | Zone A / B | Zone B / C | Zone C / D |
|---|---|---|---|
| Group 1 — rigid Above 300 kW (up to 50 MW) or electrical machine with H ≥ 315 mm; rigid support | 2.3 | 4.5 | 7.1 |
| Group 2 — rigid ★ Above 15 kW up to 300 kW or electrical machine with 160 ≤ H < 315 mm; rigid support | 1.4 | 2.8 | 4.5 |
| Group 1 — flexible Above 300 kW (up to 50 MW) or electrical machine with H ≥ 315 mm; flexible support | 3.5 | 7.1 | 11.0 |
| Group 2 — flexible Above 15 kW up to 300 kW or electrical machine with 160 ≤ H < 315 mm; flexible support | 2.3 | 4.5 | 7.1 |
The limits are for radial readings at any bearing, pedestal or housing, and for axial readings at thrust bearings only. The machine has to be in steady operation, at rated speed or inside its permitted speed range; readings taken while speed or load is changing are not judged against them. For a particular machine or unusual supports, the manufacturer and the customer may agree on other values.
The level usually seen on machines that have just been put into service.
Usually accepted for long-term running without restrictions.
Usually judged unsatisfactory for continuous long-term running. As a rule, the machine can stay in service for a limited time, until a convenient moment for corrective work.
Vibration at this level is usually considered severe enough to damage the machine.
RMS Displacement (µm)
Annex A lists displacement boundaries next to the velocity ones. If you measure both quantities, the stricter zone counts.
| Machine Group | Zone A / B | Zone B / C | Zone C / D |
|---|---|---|---|
| Group 1 — rigid | 29 | 57 | 90 |
| Group 2 — rigid ★ | 22 | 45 | 71 |
| Group 1 — flexible | 45 | 90 | 140 |
| Group 2 — flexible | 37 | 71 | 113 |
Displacement matters most on slow machines: when the once-per-revolution component dominates, a velocity that looks moderate can still mean excessive movement. For such machines the evaluation should use both velocity and displacement.
Imperial Units — RMS Velocity (in/s)
Equivalent values for regions using imperial measurement system (1 mm/s ≈ 0.03937 in/s)
| Machine Group | Zone A / B | Zone B / C | Zone C / D |
|---|---|---|---|
| Group 1 — rigid | 0.091 | 0.177 | 0.280 |
| Group 2 — rigid ★ | 0.055 | 0.110 | 0.177 |
| Group 1 — flexible | 0.138 | 0.280 | 0.433 |
| Group 2 — flexible | 0.091 | 0.177 | 0.280 |
⚡ Vibration Zone Calculator
Choose the machine group and support class, enter your readings and get the zone, the change check and ALARM/TRIP guidance based on ISO 10816-3:2009.
Rigid: the lowest natural frequency is at least 1.25 times the excitation frequency. Flexible: any other case.
Not sure about the support class? Check it
Visual Comparison of Zone Boundaries
The proportional width of each zone shows how limits expand for flexibly mounted and larger machines.
Each segment carries its upper boundary in mm/s RMS; the scale runs to 15 mm/s.
What is ISO 10816-3?
ISO 10816-3 is Part 3 of the ISO 10816 series, which evaluates machine vibration measured on parts that do not rotate. Part 1 sets out the general approach; Part 3 turns it into concrete criteria for industrial machine sets above 15 kW with nominal speeds from 120 to 15,000 r/min, measured in situ. This page describes the second edition, ISO 10816-3:2009, prepared by ISO technical committee TC 108, subcommittee SC 2.
The 2009 edition replaced the first edition of 1998. Its main change was to take pumps out of the scope, because rotodynamic pumps now have their own part, ISO 10816-7.
Vibration is judged in two ways: by its magnitude (Criterion I, zones A to D) and by how much it has changed from an established reference value (Criterion II). Annex A gives the zone boundaries in broadband RMS velocity and displacement, separately for two machine groups and for rigid and flexible supports.
General principles: ISO 10816-1
Scope and Applicability
Check the scope before using the tables: the limits are intended only for the machine types listed below, measured on site under steady running conditions.
Machines Covered
Machine sets rated above 15 kW that operate between 120 and 15,000 r/min, namely:
- steam turbines of up to 50 MW;
- larger steam turbine sets (above 50 MW) that run slower than 1,500 or faster than 3,600 r/min, speeds that ISO 10816-2 leaves out;
- rotary compressors;
- industrial gas turbines up to 3 MW;
- generators;
- electric motors of all types;
- blowers and fans.
For fans, the criteria generally suit only units above 300 kW or fans that are not flexibly supported. Other fans, for example light sheet-metal designs, need limits agreed by supplier and buyer on the basis of earlier operating experience.
Fan balance and vibration requirements: ISO 14694
Machines Excluded
ISO 10816-3:2009 does not apply to:
- large turbo-generator sets on land driven by steam, above 50 MW, at 1,500, 1,800, 3,000 or 3,600 r/min (ISO 10816-2);
- gas turbine units rated above 3 MW (ISO 10816-4);
- hydraulic machine sets in power stations and pumping plants (ISO 10816-5);
- machines connected to reciprocating machinery (ISO 10816-6);
- rotodynamic pumps, including units whose impeller is mounted directly on, or rigidly fixed to, the motor shaft (ISO 10816-7);
- positive-displacement rotary compressors, for example screw compressors;
- piston (reciprocating) compressors and pumps;
- submersible motor-pump units;
- wind turbines.
Only vibration that originates in the machine set is considered, not vibration transmitted to it from outside. Machines with gearboxes or rolling-element bearings are included, but assessing the state of such gears or bearings is not part of the standard. The same criteria serve acceptance tests and operational monitoring, whether measurements are continuous or periodic.
Power Range
Machine sets above 15 kW. For electrical machines the group follows from the shaft height; smaller machines fall outside this part.
Speed Range
Nominal operating speeds from 120 to 15,000 r/min. Readings are taken in steady operation within that range.
Measurement Location
Bearings, bearing pedestals or housings: exposed, normally accessible points that reflect the bearing housing vibration without local resonance. If a housing cannot be reached, measure as close to it as possible.
Measurement Parameter
Broadband RMS velocity in mm/s is the main quantity; displacement in µm is added when low-frequency content is expected. The band is 10–1000 Hz, or 2–1000 Hz below 600 r/min, and the instruments should meet ISO 2954.
What RMS means: RMS velocity
Machine Classification: Two Groups and Two Support Types
ISO 10816-3 sorts machines by type, by rated power or shaft height, and by the flexibility of their supports. There are two machine groups; either can have a horizontal, vertical or inclined shaft and be mounted rigidly or flexibly.
| Group | Rated power | Electrical machines | Typical design | Limits |
|---|---|---|---|---|
| 1 | Above 300 kW (Table A.1 is stated up to 50 MW) | Shaft height H ≥ 315 mm | Usually sleeve bearings; speeds across the whole 120–15,000 r/min range | Table A.1 |
| 2 ★ | More than 15 kW, not more than 300 kW | Shaft height 160 mm ≤ H < 315 mm | Usually rolling-element bearings; speeds above 600 r/min | Table A.2 |
Shaft height H is defined in ISO 496 as the distance from the shaft centreline to the machine's own mounting plane, measured on the machine as delivered. For a machine without feet, with raised feet or mounted vertically, use the shaft height of the horizontal foot-mounted version with the same frame; if the frame is not known, take half the machine's diameter.
How to Determine the Support Class
Support class is a dynamic property, not a matter of foundation material or mass. In a given measurement direction the support counts as rigid when the first natural frequency of machine and support together lies at least 25% above the main excitation frequency, which in most cases is the running speed. In every other case it counts as flexible.
The same installation can be rigid in one direction and flexible in another. Rubber or spring mounts, a concrete pad, or a steel frame do not by themselves establish the classification. Use measured or calculated natural frequencies and the relevant operating excitation.
Typical cases: large and medium electric motors, especially low-speed ones, usually stand on rigid supports, while turbo-generators and compressors above 10 MW, as well as vertical machine sets, usually have flexible ones.
If drawings and calculations do not settle the question, the standard allows the support class to be found by testing. In practice this is often an impact test or a run-up or coast-down measurement that reveals the lowest natural frequency.
Background: natural frequency
Guidance on Practical Application
The same criteria are used for acceptance tests of new or repaired machines and for monitoring machines in service; what differs is how the results are used.
Acceptance Testing of New/Repaired Equipment
The zone boundaries are guidance, not a ready-made acceptance specification: acceptance values are negotiated between the supplier and the purchaser of the machine. As a reference, the boundaries help rule out both obvious defects and unrealistic demands. Some machines justify different limits, higher or lower; the manufacturer should then give the reasons and, where more vibration is allowed, show that it does not put the machine at risk.
Operational Monitoring of In-Service Equipment
In service two questions are asked: which zone the current magnitude falls into (Criterion I), and whether it has changed significantly (Criterion II). Zones A and B give no reason for concern about long-term running, Zone C calls for corrective work at the next suitable opportunity, and Zone D means the vibration is severe enough to damage the machine. A zone describes severity; it does not identify the cause.
Criterion II compares the reading with a reference value established earlier at the same transducer position and direction, under roughly the same operating conditions. A change, upward or downward, of more than 25% of the upper boundary of Zone B counts as significant, all the more if it happens suddenly, and should start a diagnostic investigation even when Zone C has not been reached. The 25% figure is a guideline; experience with a particular machine can justify another value.
Example: for a Group 2 machine on rigid supports the upper boundary of Zone B is 2.8 mm/s, so a change of more than 0.7 mm/s is significant. A motor that has run for years at 1.0 mm/s and now reads 2.2 mm/s is still in Zone B, yet the rise of 1.2 mm/s already calls for a check.
Measurement Procedures
Readings are normally taken in two radial directions at right angles to each other on every bearing cap or pedestal. On horizontal machines these are usually the vertical and horizontal directions. On vertical or inclined machines, one of the two must be the direction with the highest reading, typically along the elastic axis. The transducers may sit at any angle around the housing, and the positions and directions used must be recorded.
For the evaluation, take the larger of the two readings in each measurement plane and compare it with the zone boundaries. A single transducer per plane is acceptable only when it is known to capture the vibration magnitude adequately, since it may not point at the maximum.
Axial vibration is not normally monitored on radial load-carrying bearings. It is measured mainly in periodic surveys or for diagnostics, because some faults show up more clearly in that direction, and the zone boundaries apply to axial readings only on thrust bearings.
Take readings once the rotor and main bearings are at their usual steady running temperature, with the machine operating under defined conditions such as rated speed and load, voltage, flow and pressure. If speed or load varies in service, measure at every condition the machine runs in for long periods and use the highest value.
If a reading exceeds the acceptance value and background vibration is suspected, repeat the measurement with the machine stopped. When the vibration at standstill is more than 25% of the running value, the external influence may have to be reduced, or separated out, for example by spectrum analysis.
Instruments should meet ISO 2954 and measure broadband RMS with a flat response over no less than 10–1000 Hz, extended down to 2 Hz for machines at or below about 600 r/min. Mount the transducers so that the mounting does not distort the reading, and watch for temperature changes, magnetic and sound fields, supply variations, cable length and transducer orientation.
Field practice, not part of ISO 10816-3: comparing directions helps narrow down likely causes during diagnostics.
| Direction | Abbreviation | Common Defects Detected |
|---|---|---|
| Horizontal (perpendicular to shaft) | H | Unbalance, looseness, bearing wear |
| Vertical | V | Unbalance, structural resonance |
| Axial (parallel to shaft) | A | Misalignment, bent shaft, thrust bearing faults |
ISO 10816-3 evaluates broadband vibration without looking at individual frequency components or phase. That is usually enough for acceptance tests and routine monitoring, but it shows that something has changed rather than what caused it. Amplitude and phase of individual components are valuable for long-term condition monitoring and diagnostics, yet criteria for them lie outside this standard.
Finding the cause: frequency spectrum analysis
Practical Examples
Step-by-step evaluations using ISO 10816-3 zone criteria.
Machine: Electric motor, 75 kW, shaft height 280 mm
Support: Concrete foundation; in the measured direction the lowest natural frequency is well above 1.25 times the running frequency, so the support is rigid
Classification: Group 2 (electrical machine with 160 mm ≤ H < 315 mm), rigid support
Measured vibration: 3.5 mm/s RMS on the drive-end bearing housing, horizontal: the larger of the two radial readings
Group 2 boundaries: A/B = 1.4 mm/s · B/C = 2.8 mm/s · C/D = 4.5 mm/s
3.5 mm/s lies between the B/C boundary (2.8) and the C/D boundary (4.5). The motor should not stay in continuous long-term service at this level, although it can usually keep running for a limited time while corrective work is planned. Typical causes to check with spectrum analysis are unbalance, misalignment and early bearing wear.
Machine: Centrifugal fan with a 500 kW drive, 1480 r/min; above 300 kW, so the fan criteria of this part apply
Support: Steel frame on spring isolators; in the measured direction the lowest natural frequency is below 1.25 times the running frequency, so the support is flexible
Classification: Group 1 (above 300 kW), flexible support
Measured vibration: 2.0 mm/s RMS, the larger of the two radial readings on the drive-end bearing
Group 1, flexible-support boundaries: A/B = 3.5 mm/s · B/C = 7.1 mm/s · C/D = 11.0 mm/s
2.0 mm/s is below the A/B boundary of 3.5 mm/s, the level typical of a newly commissioned machine. Whether the fan passes acceptance still depends on the values agreed between supplier and customer.
Machine: Electric motor, 45 kW, shaft height 225 mm
Support: Rubber mounts; in the measured direction the lowest natural frequency is below 1.25 times the running frequency, so the support is flexible
Classification: Group 2, flexible support
Baseline vibration: 3.0 mm/s RMS (established 6 months ago)
Current vibration: 6.8 mm/s RMS
Group 2, flexible-support boundaries: A/B = 2.3 mm/s · B/C = 4.5 mm/s · C/D = 7.1 mm/s
6.8 mm/s lies between 4.5 and 7.1 mm/s, so the magnitude is in Zone C. The rise of 3.8 mm/s is far above the 1.125 mm/s guideline (25% of the 4.5 mm/s B/C boundary), so Criterion II also calls for a diagnostic investigation. With a baseline of 3.0 mm/s the recommended ALARM would have been 4.125 mm/s.
Key Concepts and Best Practices
Guidance, Not a Contract
Zone boundaries are reference values. Acceptance limits come from agreement between supplier and customer, while ALARM and TRIP settings come from the baseline and design of the machine.
Support Class Matters
The same reading can fall into different zones for Group 1 and Group 2, and for rigid and flexible supports. Classify the machine and the support in each direction before reading the table.
Watch the Change
A machine running steadily at 2.5 mm/s is less worrying than one that jumped from 1.0 to 2.5 mm/s. For Group 2 on rigid supports, any change above 0.7 mm/s counts as significant under Criterion II.
Screening, Not Diagnosis
The standard evaluates overall broadband vibration: it shows that a problem exists, not what it is. For the root cause, use spectral analysis, time waveform analysis and phase measurements with a vibration analyzer.
Operational Limits: ALARM and TRIP
For long-term operation ISO 10816-3 describes two kinds of operational limits. An ALARM warns that vibration has reached a set value or has changed significantly; the machine can usually keep running while the cause is investigated. A TRIP marks the level beyond which further running may damage the machine; once it is exceeded, vibration should be reduced at once or the machine shut down. Limits may differ between measurement positions and directions.
Setting the ALARM
Set the ALARM relative to the steady-state baseline of that machine at that position and direction: baseline plus 25% of the upper boundary of Zone B. The ALARM should normally stay at or below 125% of that boundary, and with a low baseline it may lie below Zone C. A new machine without a baseline starts from experience with similar machines or from the agreed acceptance values; the setting is adjusted once a steady baseline is known, and again whenever the baseline shifts, for example after an overhaul.
Setting the TRIP
TRIP limits depend on the mechanical integrity and the design of the machine, so they are usually the same for machines of similar design and are not tied to the baseline. The standard gives no fixed TRIP values. The TRIP normally lies in Zone C or D and should be no higher than 125% of the Zone C upper boundary.
Upper limits for settings, mm/s RMS
Derived from the velocity boundaries: 25% and 125% of B/C, 125% of C/D
| Machine Group | Significant change | ALARM, max. | TRIP, max. |
|---|---|---|---|
| Group 1 — rigid | 1.125 | 5.625 | 8.875 |
| Group 2 — rigid ★ | 0.700 | 3.500 | 5.625 |
| Group 1 — flexible | 1.775 | 8.875 | 13.750 |
| Group 2 — flexible | 1.125 | 5.625 | 8.875 |
Example: a Group 2 machine on rigid supports with a baseline of 1.2 mm/s gets an ALARM of 1.2 + 0.7 = 1.9 mm/s, well under the 3.5 mm/s ceiling, and a TRIP no higher than 5.625 mm/s.
Setting up the reference value: vibration baseline
Relationship to Other Standards
ISO 10816-3 relies on ISO 10816-1 for the general guidelines, on ISO 2954 for the requirements on vibration severity instruments and on ISO 496 for shaft heights. Machines excluded here are covered by other parts of the series: ISO 10816-2 (large steam turbines and generators in land-based power plants), ISO 10816-4 (gas turbine sets), ISO 10816-5 (hydraulic power and pumping plants), ISO 10816-6 (reciprocating machines) and ISO 10816-7 (rotodynamic pumps).
Bearing housing criteria can be supplemented by shaft vibration measured according to ISO 7919-3. There is no simple conversion between housing and shaft vibration, so both have to be measured independently; if the two sets of criteria lead to different assessments, the more restrictive one applies. ISO has since withdrawn the 2009 edition, and its revision is ISO 20816-3:2022.
Related pages: ISO 7919-1 · ISO 20816-3
Frequently Asked Questions
An electrical machine with a shaft height of at least 160 mm but less than 315 mm belongs to Group 2. On rigid supports its A/B, B/C and C/D boundaries are 1.4, 2.8 and 4.5 mm/s RMS (22, 45 and 71 µm); on flexible supports they are 2.3, 4.5 and 7.1 mm/s (37, 71 and 113 µm).
The distinction is dynamic and is made separately for each measurement direction. The support is rigid when the lowest natural frequency of machine and support together is at least 25% above the main excitation frequency, and flexible in every other case. Foundation material or the presence of isolators does not decide it on its own.
ISO lists ISO 10816-3:2009 as withdrawn; its revision is ISO 20816-3:2022. This page describes the 2009 edition.
No. ISO 10816-3 covers machine sets above 15 kW, so smaller machines are outside its scope. For them, rely on the manufacturer's limits or other applicable criteria and track changes against a baseline recorded after installation.
No. The 2009 edition took pumps out of the scope. Rotodynamic pumps, including designs with an integrated motor, are handled by ISO 10816-7, while reciprocating pumps and submerged motor-pumps are excluded.
Set the ALARM at the steady-state baseline plus 25% of the upper boundary of Zone B, normally no higher than 125% of that boundary. The TRIP depends on the machine design, usually lies in Zone C or D and should stay at or below 125% of the Zone C upper boundary.
Not as routine. The evaluation is based on two radial directions per bearing. Axial readings are mainly used in periodic surveys and diagnostics, and the zone limits apply to them only on thrust bearings.
Official ISO Standard
Catalogue entry of the document described on this page: ISO 10816-3:2009 on iso.org
This page is an independent summary written in our own words for educational purposes. It does not reproduce the text of the standard; for normative requirements, use the official document.
← Back to Main Glossary Index